Sitemap
A list of all the posts and pages found on the site. For you robots out there is an XML version available for digesting as well.
Pages
Posts
Future Blog Post
Published:
This post will show up by default. To disable scheduling of future posts, edit config.yml and set future: false.
Blog Post number 4
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
Blog Post number 3
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
Blog Post number 2
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
Blog Post number 1
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
findings
portfolio
Traffic Rule Compliant AVs using end-to-end RL
Ongoing project on using end-to-end RL with Reward Machines to encode traffic rule compliance into the RL learned policy.

Queens Game Solver
Solving the queens game from linkedin using the Theorem Prover z3.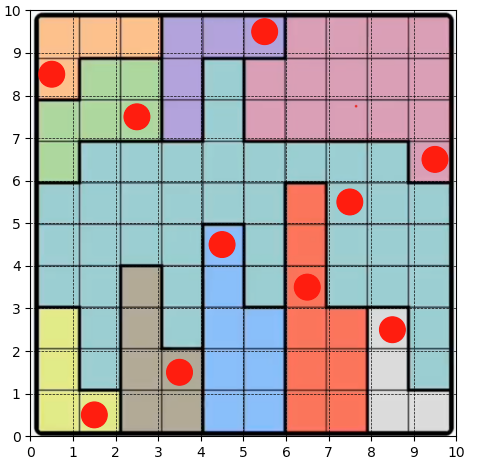
publications
Outlier-robust inverse reinforcement learning and reward-based detection of anomalous driving behaviors
Published in 2022 IEEE 25th International Conference on Intelligent Transportation Systems (ITSC), 2022
This paper is about perfomring anomally detection using LP Inverse Reinforcement Learning.
Recommended citation: Li, D., Shehab, M. L., Liu, Z., Aréchiga, N., DeCastro, J., & Ozay, N. (2022, October). Outlier-robust inverse reinforcement learning and reward-based detection of anomalous driving behaviors. In 2022 IEEE 25th International Conference on Intelligent Transportation Systems (ITSC) (pp. 4175-4182). IEEE.
Download Paper
Learning true objectives: Linear algebraic characterizations of identifiability in inverse reinforcement learning
Published in 6th Annual Learning for Dynamics & Control Conference (L4DC), 2024
This paper is about the Identifiability of Max Entropy Inverse Reinforcement Learning.
Recommended citation: Shehab, M. L., Aspeel, A., Aréchiga, N., Best, A., & Ozay, N. (2024, June). Learning true objectives: Linear algebraic characterizations of identifiability in inverse reinforcement learning. In 6th Annual Learning for Dynamics & Control Conference (pp. 1266-1277). PMLR.
Download Paper
Learning Reward Machines from Partially Observed Policies
Published in Transactions on Machine Learning Research (TMLR), 2025
This paper deals with learning reward machines (FSM) from partial expert policies.
Efficient Reward Identification In Max Entropy Reinforcement Learning with Sparsity and Rank Priors
Published in 2025 IEEE 64th Conference on Decision and Control (CDC), 2025
This paper is about infusing computationally efficient priors for learning rewards in Max Entropy Inverse Reinforcement Learning.
Recommended citation: Shehab, M. L., Tercan, A., & Ozay, N. (2025). Efficient Reward Identification In Max Entropy Reinforcement Learning with Sparsity and Rank Priors. In 2025 IEEE 64th Conference on Decision and Control (CDC). IEEE.
Download Paper
Active Reward Machine Inference From Raw State Trajectories
Published in 17th World Symposium on the Algorithmic Foundations of Robotics (WAFR), 2026
Actively inferring reward machines from raw state trajectories.
TAP-VLA: Tactile Annotation Prompting for Vision Language Action Models
Published in arXiv preprint arXiv:2606.29089, 2026
Supplying tactile feedback to vision-language-action models through visual augmentation.
Traffic Rule Compliant Autonomous Driving Using Reward Machines and Reinforcement Learning
Published in 2026 IEEE 29th International Conference on Intelligent Transportation Systems (ITSC), 2026
Encoding history-dependent traffic rules as reward machines for reinforcement learning.
talks
Talk 1 on Relevant Topic in Your Field
Published:
This is a description of your talk, which is a markdown files that can be all markdown-ified like any other post. Yay markdown!
Conference Proceeding talk 3 on Relevant Topic in Your Field
Published:
This is a description of your conference proceedings talk, note the different field in type. You can put anything in this field.
teaching
ROB 501 - Math for Robotics
Graduate Course, University of Michigan, Robotics Department, 2025
Topics covered include: Abstract Algebra, Least Squares, Kalman Filtering, Real Analysis.
ROB 101 - Computational Linear Algebra
Undergraduate Course, University of Michigan, Robotics Department, 2025
Topics covered include: Julia programming language. Systems of linear equations. Vectors, matrices, inverses. Regression. Matrix factorization. Spatial coordinates. Cameras, LiDARS, accelerometers, single-axis gyroscopes, encoders. Optimization and robot perception. What is an ODE.