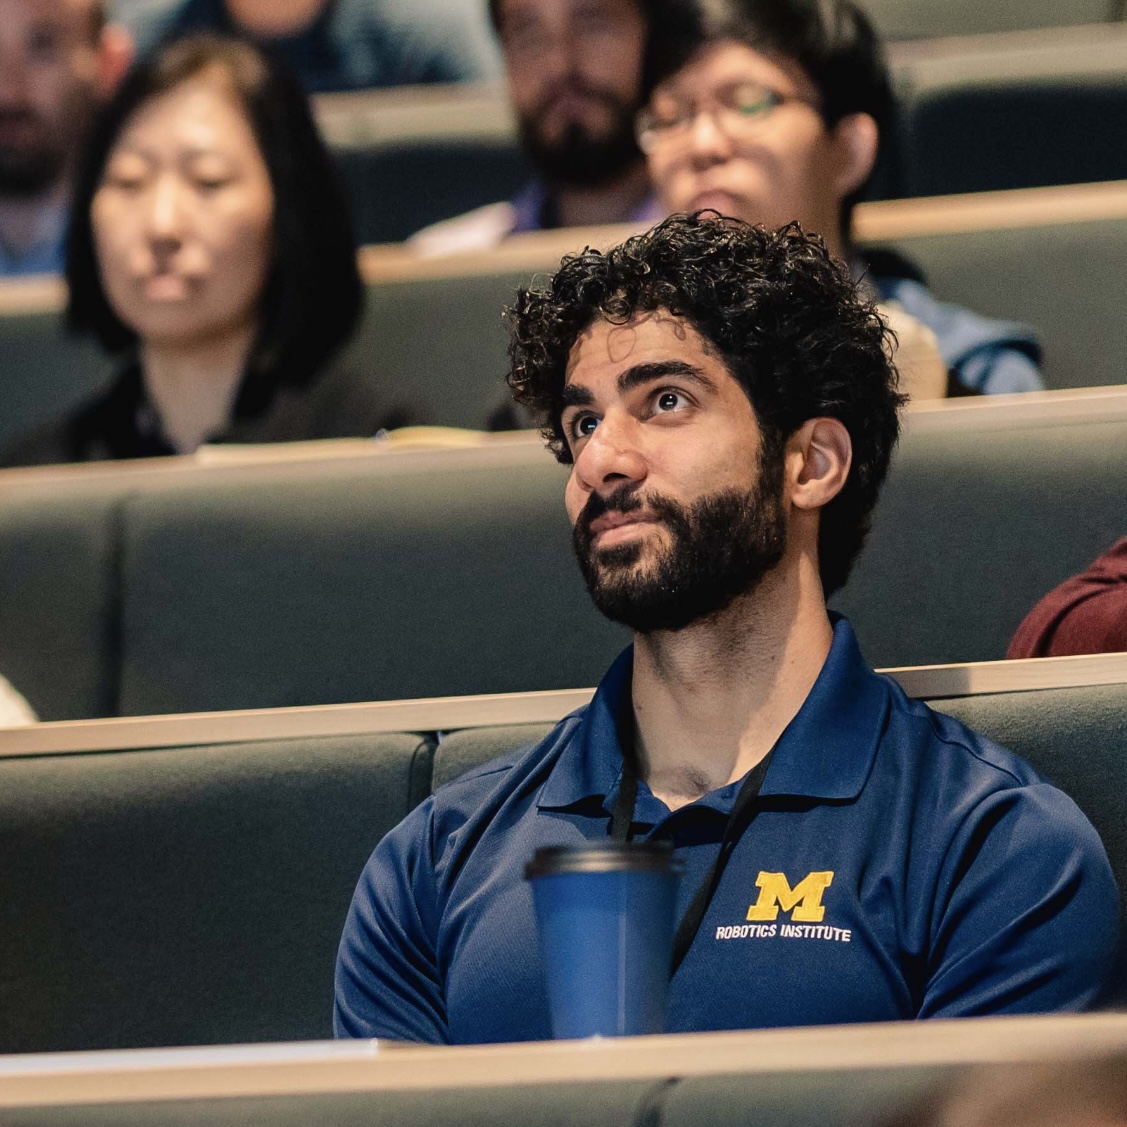
Mohamad Louai Shehab
Welcome !
I’m Mohamad Louai Shehab, a postdoctoral researcher in the Robotics Department at the University of Michigan, working with Prof. Nima Fazeli. I received my Ph.D. in Robotics from the University of Michigan, advised by Prof. Necmiye Ozay.
My current research focuses on vision-language-action (VLA) policies for industrial settings, where high success rates are required. I am also interested in integrating memory components efficiently into these models.
My Ph.D. research focused on extending inverse reinforcement learning to the non-Markovian setting by making use of reward machines, drawing on techniques from SAT/Max-SAT theory, linear algebra, optimization, and statistics. This research was recognized with the Outstanding Student Paper Award at CDC 2025.
Bio
I was born in Beirut, Lebanon. I received an embedded M.Sc. in Robotics from the University of Michigan in 2024. Before that, I obtained a B.E. in Mechanical Engineering and a B.S. in Applied Mathematics from the American University of Beirut in 2021, both with high distinction. My research has been supported by grants from Toyota Research Institute (TRI), the Office of Naval Research (ONR), and the Robotics Department Graduate Fellowship.
Latest News
Oct. 2026 - I became a Visiting Scientist at General Motors.
Sep. 2026 - I was selected by the Robotics Graduate Program Committee to be nominated for the ProQuest Distinguished Dissertation Award!
Sep. 2026 - I joined Voxel51 as a Robotics Technical Writer.
Jun. 2026 - I started as a postdoctoral researcher working with Prof. Nima Fazeli at the University of Michigan.
Apr. 2026 - Our paper Active Reward Machine Inference From Raw State Trajectories has been accepted to the 17th World Symposium on the Algorithmic Foundations of Robotics (WAFR)!
Mar. 2026 - I defended my Ph.D. thesis!
Feb. 2026 - I gave an invited talk in professor Peter Seiler group in the ECE department at University of Michigan. I talked about my most recent work on learning reward machines with unknown labels, currently under review.
Dec. 2025 - Our paper Efficient Reward Identification in Max Entropy Reinforcement Learning with Sparsity and Rank Priors has won the Outstanding Student Paper Award at CDC’2025!
Oct. 2025 - Our paper Learning Reward Machines from Partially Observed Policies is accepted at Transactions on Machine Learning Research (TMLR), 2025!
Jun. 2025 - I passed my thesis proposal exam! I’ll be defending my thesis in approximately 1 year.
Jan. 2025 - I was at the Purdue ICON Student Research Conference in West Lafayette, IN. I presented a poster about our work Learning Reward Machines from Partially Optimal Policies
Jul. 2024 — I was at the Learning for Dynamics and Control Conference (L4DC) to present our work Learning true objectives: Linear algebraic characterizations of identifiability in inverse reinforcement learning.
Apr. 2024 — I was at the Midwest Workshop on Control and Game Theory in Chicago, IL. I presented a poster about our accepted L4DC paper.
Jan. 2024 I was elected to be the Colloqium Chair in the Robotics Graduate Student Council (RGSC).
Jan. 2023 I was elected to be the Outreach Chair in the Robotics Graduate Student Council (RGSC).
Dec. 2022 - I passed my CQE exam and became a Ph.D Candidate.
Jul. 2022 - I attended the Formal Methods in Control Design workshop organized by European Embedded Control Institute (EECI).